STEP-to-voxel conversion
The STEPtoVoxel toolbox converts STEP CAD assemblies into cell-labelled
voxel grids that can be imported by gprMax with
GeometryObjectsRead/#geometry_objects_read. It preserves assembly
components, provides an editable part-to-material mapping, resolves overlaps
using explicit priorities, and can export a VTK ImageData file for inspection
in ParaView. Every included component also becomes a cell-centred semantic
geometry tag by default.
The toolbox is based on the STEP-to-gprMax project developed by Mahdee
Abir as part of an MEng project at the University of Edinburgh. The original
project is distributed under the MIT License; its copyright and licence notice
are retained in LICENSE.
The slice-based voxelisation work also builds on ideas from Christian
Pederkoff’s stl-to-voxel project.
Installation
STEP reading and tessellation require OpenCascade’s Python bindings. Install them from conda-forge in the environment used to run gprMax:
conda install -c conda-forge pythonocc-core
NumPy and h5py are already gprMax dependencies. PyVista is optional and is
only required for direct .vti export and interactive voxel visualisation:
conda install -c conda-forge pyvista
The toolbox imports OpenCascade and PyVista lazily. Normal gprMax usage is therefore unaffected when these optional packages are absent.
Workflow
First inspect the components and dimensions contained in a STEP file:
python -m gprMax.toolboxes.STEPtoVoxel inspect model.stp \
    --voxel-size 0.0001 0.0001 0.0001
Create an editable material-assignment file:
python -m gprMax.toolboxes.STEPtoVoxel prepare model.stp materials.csv \
    --voxel-size 0.0001 0.0001 0.0001
By default, repeated occurrences of the same STEP shape definition share one
CSV row. For example, an assembly containing many instances of one screw needs
only one material characterisation. The part_names column lists every
member and group_confidence=exact_instance explains why they were grouped.
The user can split a row into two rows and partition part_names whenever
instances require different materials.
The optional geometry_tag column is independent of material_name. A
blank value gives every source component its own sanitised component-name tag.
Enter one shared value, for example fasteners, when all components in a
row should be selected collectively in later output processing. Several
components may share a material without sharing a tag, or share a tag while
using different materials.
The similar_group column reports geometrically similar candidates without
combining them. Approximate grouping is available explicitly when preparing
the file:
python -m gprMax.toolboxes.STEPtoVoxel prepare model.stp materials.csv \
    --group-mode similar --group-tolerance 0.01
This comparison uses volume, surface area, topology and principal moments.
It cannot prove that two shapes or their materials are identical, so every
similar_candidate group must be inspected before properties are entered.
Use --group-mode none to retain one row per component. Reusing exactly the
same material name and properties in separate rows still stores only one
material in the output. Higher priorities overwrite lower priorities where
CAD solids overlap. The converter also accepts the earlier one-row-per-part
CSV format.
After editing the CSV, perform the conversion:
python -m gprMax.toolboxes.STEPtoVoxel convert model.stp materials.csv output \
    --voxel-size 0.0001 0.0001 0.0001
This creates:
geometry.h5– theint16material grid and compact semantic tag grid read by gprMax;materials.json– a versioned material database whose keys are stored ingeometry.h5;markers.json– reusable CAD source, receiver and port coordinates;geometry.vti– component-labelled VTK ImageData for ParaView;reference_geometry_cad.vtp– non-physical CAD ports, source edges, points and construction faces in the original CAD coordinate system;conversion.json– dimensions, origin, component mapping and voxel counts.
Use --no-vtk if PyVista is not installed.
STEP files describe geometry and component names, but do not provide the electromagnetic constitutive properties required by gprMax. The assignment CSV and generated JSON database therefore serve different purposes. Use the CSV to select and group CAD components, set overlap priority, and map them to stable material names. Its property columns can seed simple constant values, but they are not inferred from STEP and must be supplied by the user.
GeometryObjectsRead consumes the generated materials.json together
with geometry.h5. This JSON file is the authoritative runtime database:
review or edit it directly to provide the required properties, dispersion,
metadata, and citations. Keep the HDF5 and JSON files as a pair. A later
conversion preserves an existing JSON file when its stable material keys
still match. If the component-to-material mapping changes, the converter
stops and asks the user to move the old JSON aside rather than silently
discarding its edited properties.
Only material_name is required for an included CSV row. Constitutive
property columns may be left blank; the converter then writes null values
to make the missing assignments explicit. gprMax will reject such an entry
until the corresponding values in materials.json have been completed.
Material names must not contain +: gprMax reserves it for automatically
averaged material IDs. Use _ instead in material_name. The same
restriction applies to name and metadata.original_id when the
converter reuses an edited companion JSON database. CAD part names are not
material assignments and need not be renamed. This does not restrict averaged
materials restored from files produced by gprMax’s GeometryObjectsWrite.
Coordinate systems
geometry.vti and reference_geometry_cad.vtp retain the original CAD
coordinate system and overlay directly in ParaView. geometry.h5 is a
local index grid: GeometryObjectsRead translates it to the model position
given by p1. A gprMax GeometryView therefore uses model coordinates,
not the original CAD coordinates.
To overlay the CAD references on a gprMax GeometryView, translate them by
The helper below writes a translated copy while preserving the original VTP:
from gprMax.toolboxes.STEPtoVoxel import translate_reference_geometry

translation = tuple(
    import_origin[axis] - conversion_result.origin[axis]
    for axis in range(3)
)
translate_reference_geometry(
    conversion_result.reference_geometry_cad_file,
    "reference_geometry_gprmax.vtp",
    translation,
)
The converter always writes the CAD-coordinate file. It cannot write the
gprMax-coordinate file until the model author chooses p1. The example
script writes that translated file from the same import_origin passed to
GeometryObjectsRead; the gprMax solver itself does not generate either
reference file.
gprMax import
The CAD coordinates are translated into a local voxel grid. The
origin_m entry in conversion.json records the original CAD-space
lower corner, while p1 specifies where that local grid is inserted into
the gprMax domain:
scene.add(
    gprMax.GeometryObjectsRead(
        p1=(0.01, 0.01, 0.01),
        geofile="output/geometry.h5",
        material_database="materials",
    )
)
The gprMax discretisation must exactly match the voxel size recorded in
geometry.h5.
Voxelisation and thin CAD solids
The solid voxeliser intersects a tessellated component with parallel planes
and fills each closed cross-section. --sweep-axis auto uses the shortest
grid dimension and prefers z when dimensions are equal. An explicit x, y or z
axis can be selected when reproducing or diagnosing a conversion.
The default --supersample 1 evaluates the centre of every Yee cell. This
is the clearest reproducible material-assignment convention. A value greater
than one takes that number of samples along each of x, y and z and assigns a
cell when a strict majority of the resulting samples is inside. Thus a value
of two uses eight samples rather than sampling only one direction.
A closed solid thinner than one cell can lie between all cell centres and disappear. If an otherwise empty solid is thinner than one cell along x, y or z, the toolbox samples its own mid-plane and represents it with one FDTD cell along that axis. This behaviour is enabled by default. It is intended as a loss-prevention safeguard, not as a claim that an unresolved object has been modelled accurately. The generated geometry must always be inspected.
Open or zero-volume CAD faces, edges and points are not converted into solid
materials.
They are listed during inspection, default to include=n in the material
CSV, and are exported separately to reference_geometry_cad.vtp. Such
objects are often port planes, source edges, reference points or CAD
construction geometry. Load the VTP alongside geometry.vti in ParaView to
inspect them without changing the electromagnetic model.
CAD sources, receivers and ports
Non-physical CAD objects can carry source and receiver placement into the gprMax model. Give each marker a case-insensitive name beginning with one of the following portable prefixes:
gprmax_source_orsource;gprmax_receiver_,receiverorrx;gprmax_port_orport.
For example, gprmax_source_tx1, rx2 and port1 are recognised.
Markers always default to include=n and cannot be assigned physical
material by the converter.
A planar, zero-thickness face is recommended for a wave/coaxial port because
it records the aperture bounds, centre and normal axis. A CAD point is ideal
for a point source or receiver when the exporter preserves datum geometry.
An axis-aligned CAD edge is especially useful for a one-cell electric source:
markers.json records both endpoints, its midpoint, length and x, y
or z axis. The line direction sign is still arbitrary, so source polarity
must be chosen in the model.
Many exporters discard isolated points and sketch lines; in that case use a
small sphere or box whose centroid marks the position. The marker solid is
excluded from voxelisation by its name.
markers.json stores every marker in original CAD coordinates and in local
coordinates relative to geometry.h5. If the voxel geometry is imported at
p1, its model position is
The Python helper performs this translation:
from gprMax.toolboxes.STEPtoVoxel import load_markers

markers = load_markers("output/markers.json")
source_position = markers["gprmax_source_tx1"].model_position(
    geometry_import_origin=(0.01, 0.01, 0.01)
)
For surface markers the reported normal sign follows CAD tessellation and is not a reliable excitation polarity; the dominant axis is reliable for an axis-aligned plane. Excitation type, waveform, impedance, field component and polarity must still be specified in the gprMax model.
Name recovery
Different STEP exporters attach semantic names to different entities. The
reader first uses OpenCascade/XCAF labels, then maps each transferred shape
back to its exact STEP entity and searches the referenced entity graph for
shape-representation, solid/surface, product, assembly-occurrence and layer
names. The selected source and confidence are written to conversion.json
and shown by the inspect command. Representation order is used only as a
low-confidence fallback for flat files. If an exporter removes semantic names
entirely, they must be supplied manually in the material mapping.
Worked example: probe-fed patch antenna
examples/patch_antenna contains a probe-fed microstrip patch exported as
an AP242 STEP file. It provides a compact example of the complete conversion
and source-placement workflow. The six physical components are PATCH,
SUB, GROUND, INNER, DIE and OUTER. A seventh object,
port1, is the zero-volume source plane exported by the CAD program.
Important
port1 is placement metadata, not an excitation. It remains outside
geometry.h5. The user must select the gprMax source type, waveform,
propagation direction and polarity after inspecting the converted model.
The dielectric values supplied with this geometry are illustrative and must be changed to the properties of the manufactured antenna before electromagnetic results are interpreted.
1. Inspect the STEP metadata
From the repository root, list the CAD components before assigning materials:
python -m gprMax.toolboxes.STEPtoVoxel inspect \
    gprMax/toolboxes/STEPtoVoxel/examples/patch_antenna/PROBE_FED.stp \
    --voxel-size 0.00007 0.00007 0.00007
The output should contain the six solids and port1. The latter is reported
as a surface with an exact STEP name. If a source edge or receiver point were
present, they would be reported and retained in the same reference-geometry
workflow.
2. Prepare and edit material assignments
Generate an editable CSV without overwriting the supplied example:
python -m gprMax.toolboxes.STEPtoVoxel prepare \
    gprMax/toolboxes/STEPtoVoxel/examples/patch_antenna/PROBE_FED.stp \
    patch_materials.csv \
    --voxel-size 0.00007 0.00007 0.00007
Assign the real substrate and coaxial-dielectric properties. The intended roles in the supplied example are:
STEP component |
Example material |
Included |
Purpose |
|---|---|---|---|
|
PEC |
yes |
Radiating conductor |
|
dielectric |
yes |
Antenna substrate |
|
PEC |
yes |
Ground plane |
|
PEC |
yes |
Coaxial inner conductor |
|
dielectric |
yes |
Coaxial filling material |
|
PEC |
yes |
Coaxial outer conductor |
|
none |
no |
Non-physical source-plane marker |
Keep port1 as include=n. The converter rejects a marker that is
accidentally enabled as a physical material.
3. Voxelise the assembly
The 35 micrometre patch and ground metallisation require special care. The example uses a 70 micrometre grid and the thin-solid preservation described above:
python -m gprMax.toolboxes.STEPtoVoxel convert \
    gprMax/toolboxes/STEPtoVoxel/examples/patch_antenna/PROBE_FED.stp \
    gprMax/toolboxes/STEPtoVoxel/examples/patch_antenna/materials.csv \
    patch_output --voxel-size 0.00007 0.00007 0.00007
The result is a compact 290 x 290 x 41 voxel grid. The 35 micrometre patch
and ground metallisation are thinner than the 70 micrometre cells, so the
thin-solid safeguard represents each with one layer. This preserves the
conductors but does not make their physical thickness resolved.
4. Inspect the material geometry
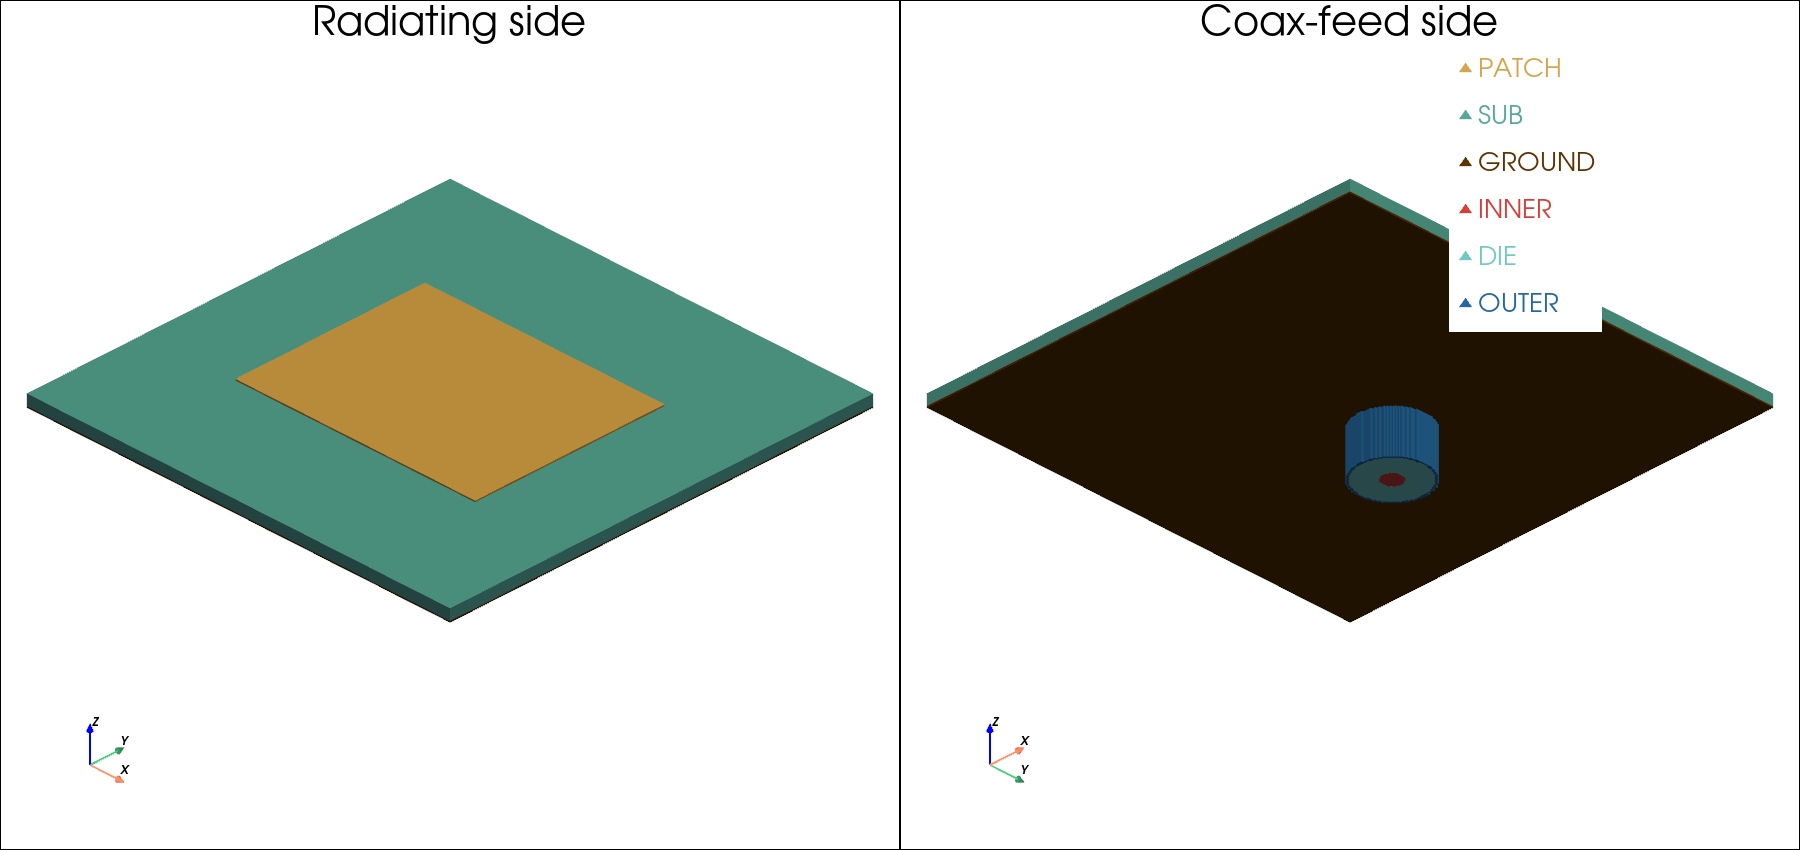
Open patch_output/geometry.vti in ParaView and colour it by
component_id. The radiating side should show a rectangular patch centred
on the substrate; the opposite side should show the coaxial inner conductor,
dielectric and outer conductor passing through the ground plane. The two views
below were rendered from this component-labelled VTK output.
5. Inspect the source reference geometry
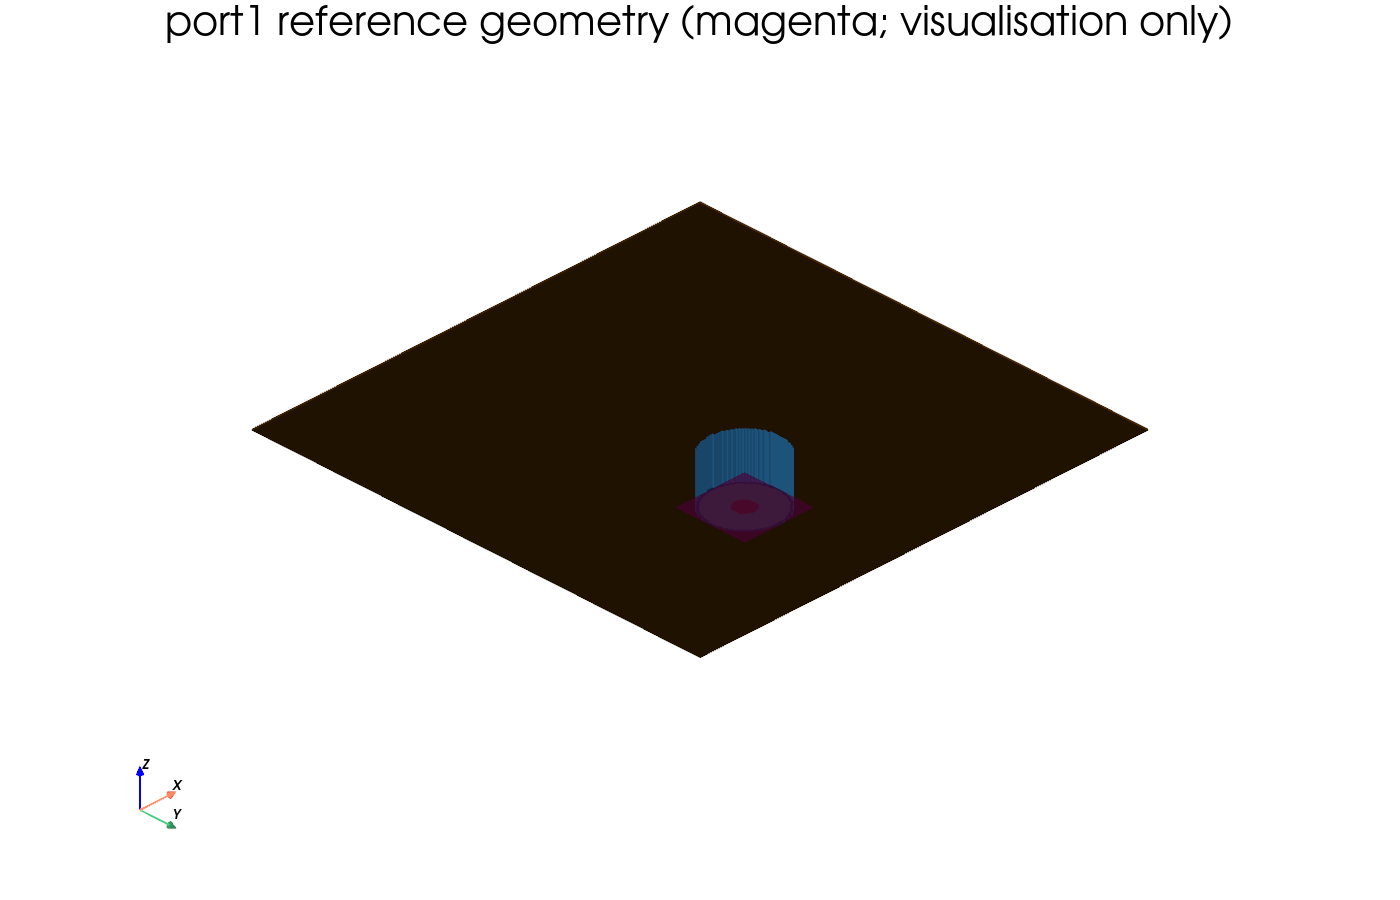
Add patch_output/reference_geometry_cad.vtp to the same ParaView pipeline.
Display it as magenta with partial opacity while leaving geometry.vti
visible. The overlay below shows the original port1 CAD plane at the
bottom of the coax feed. It is not part of the material grid.
The VTP file may also contain named source edges and receiver points. Its
reference_geometry_id cell data maps to the reference_geometry list in
conversion.json. Numerical source coordinates are obtained from
markers.json rather than by reading positions from the visualisation.
6. Import the voxel geometry into gprMax
The supplied Python example performs conversion, imports the HDF5 grid and
creates a gprMax geometry view. It also writes
output/reference_geometry_gprmax.vtp with the translation required for a
direct ParaView overlay:
python gprMax/toolboxes/STEPtoVoxel/examples/patch_antenna/patch_antenna_geometry.py
That Python example performs conversion and import in one run. After it has
created the output directory, the equivalent hash-command example can be
run with:
python -m gprMax gprMax/toolboxes/STEPtoVoxel/examples/patch_antenna/patch_antenna_geometry.in --geometry-only
The essential import is:
dl = 70e-6
import_origin = (10 * dl, 10 * dl, 10 * dl)

scene.add(gprMax.Discretisation(p1=(dl, dl, dl)))
scene.add(
    gprMax.GeometryObjectsRead(
        p1=import_origin,
        geofile="patch_output/geometry.h5",
        material_database="materials",
    )
)
The gprMax discretisation must be identical to the conversion voxel size.
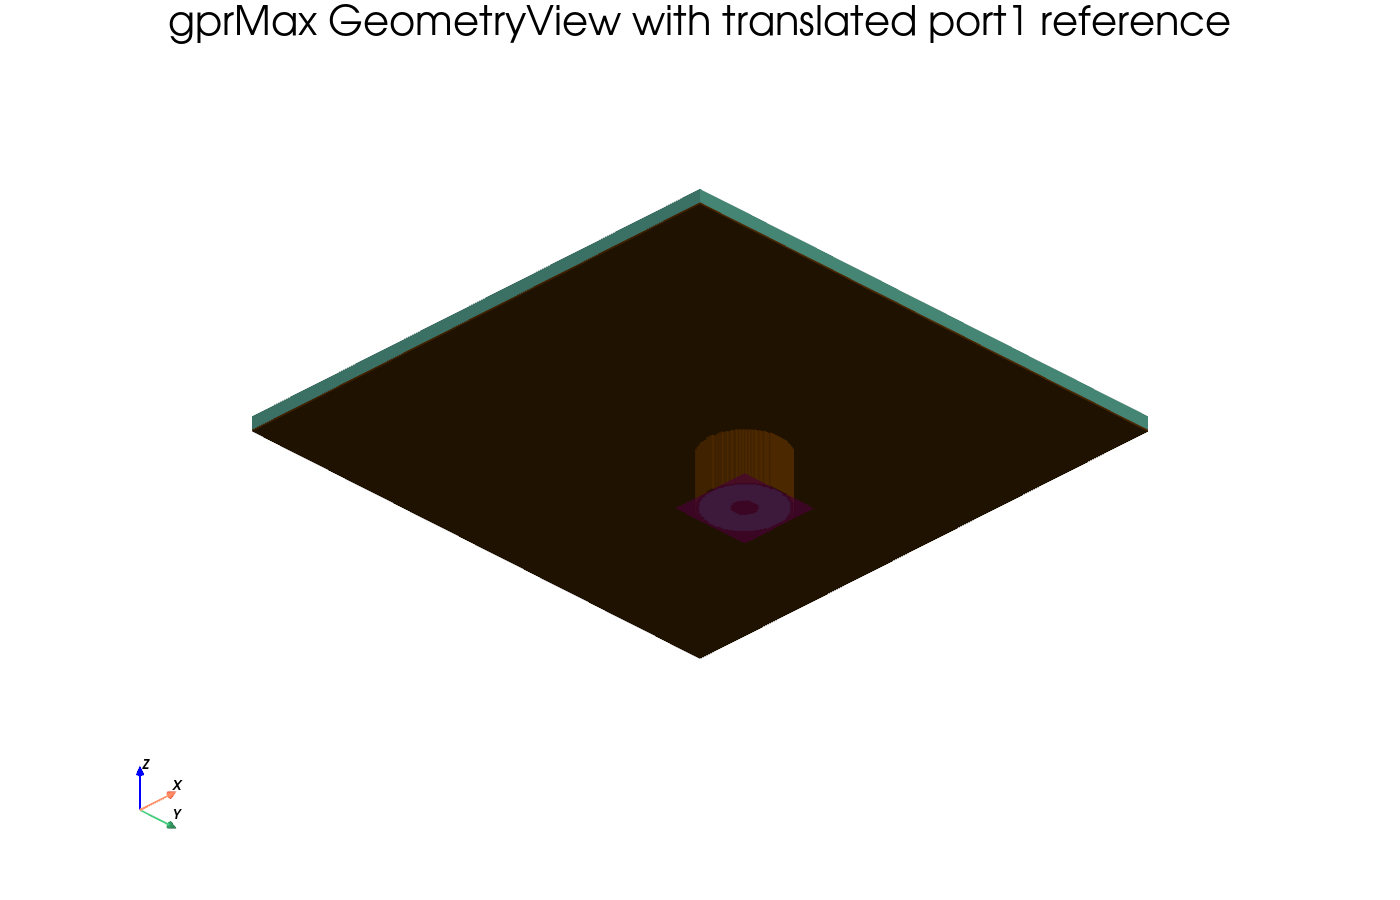
Use reference_geometry_cad.vtp with the converter VTI, or
reference_geometry_gprmax.vtp with the gprMax GeometryView. Mixing those
coordinate systems displaces the reference plane.
The image below is generated from the actual gprMax GeometryView and the translated VTP. The magenta plane now coincides with the bottom of the coaxial-feed geometry in model coordinates.
The following ParaView views were exported from
probe_fed_70um_gprmax_geometry.vtkhdf, which was produced by the actual
gprMax geometry-only run after GeometryObjectsRead imported the voxel
model. They therefore show the geometry that gprMax will use rather than the
converter preview.
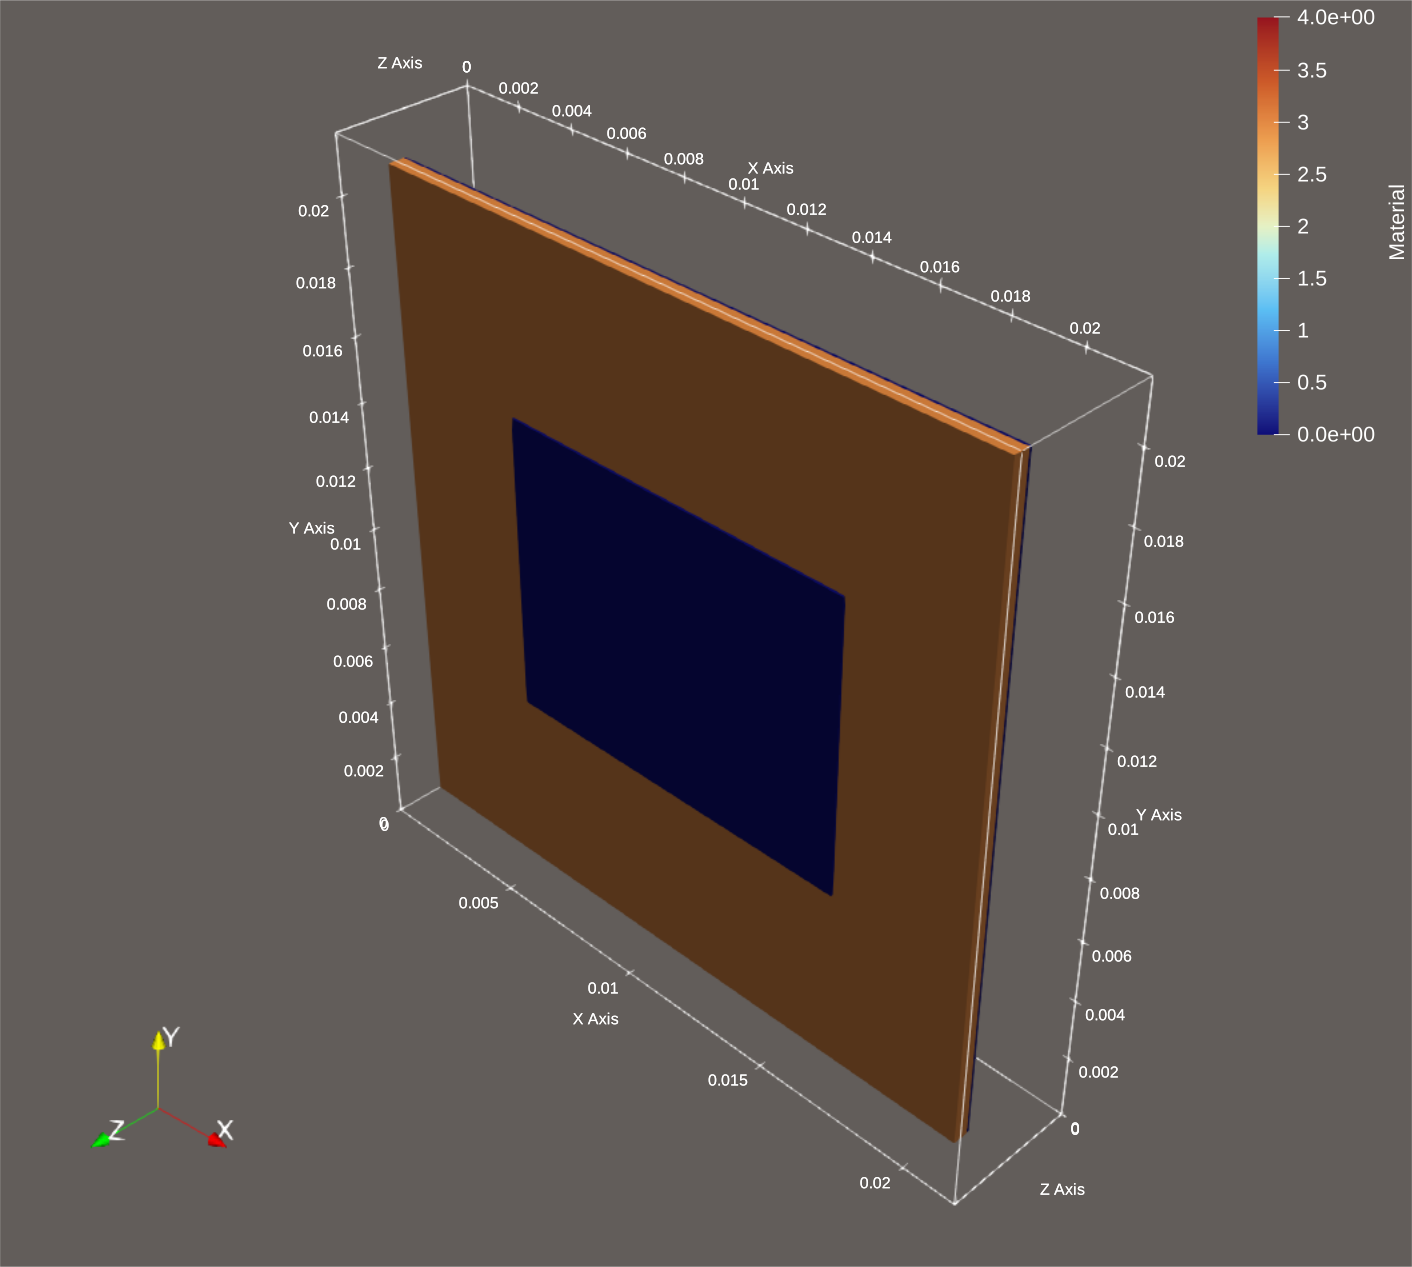
Fig. 83 Radiating patch side of the geometry imported into gprMax.
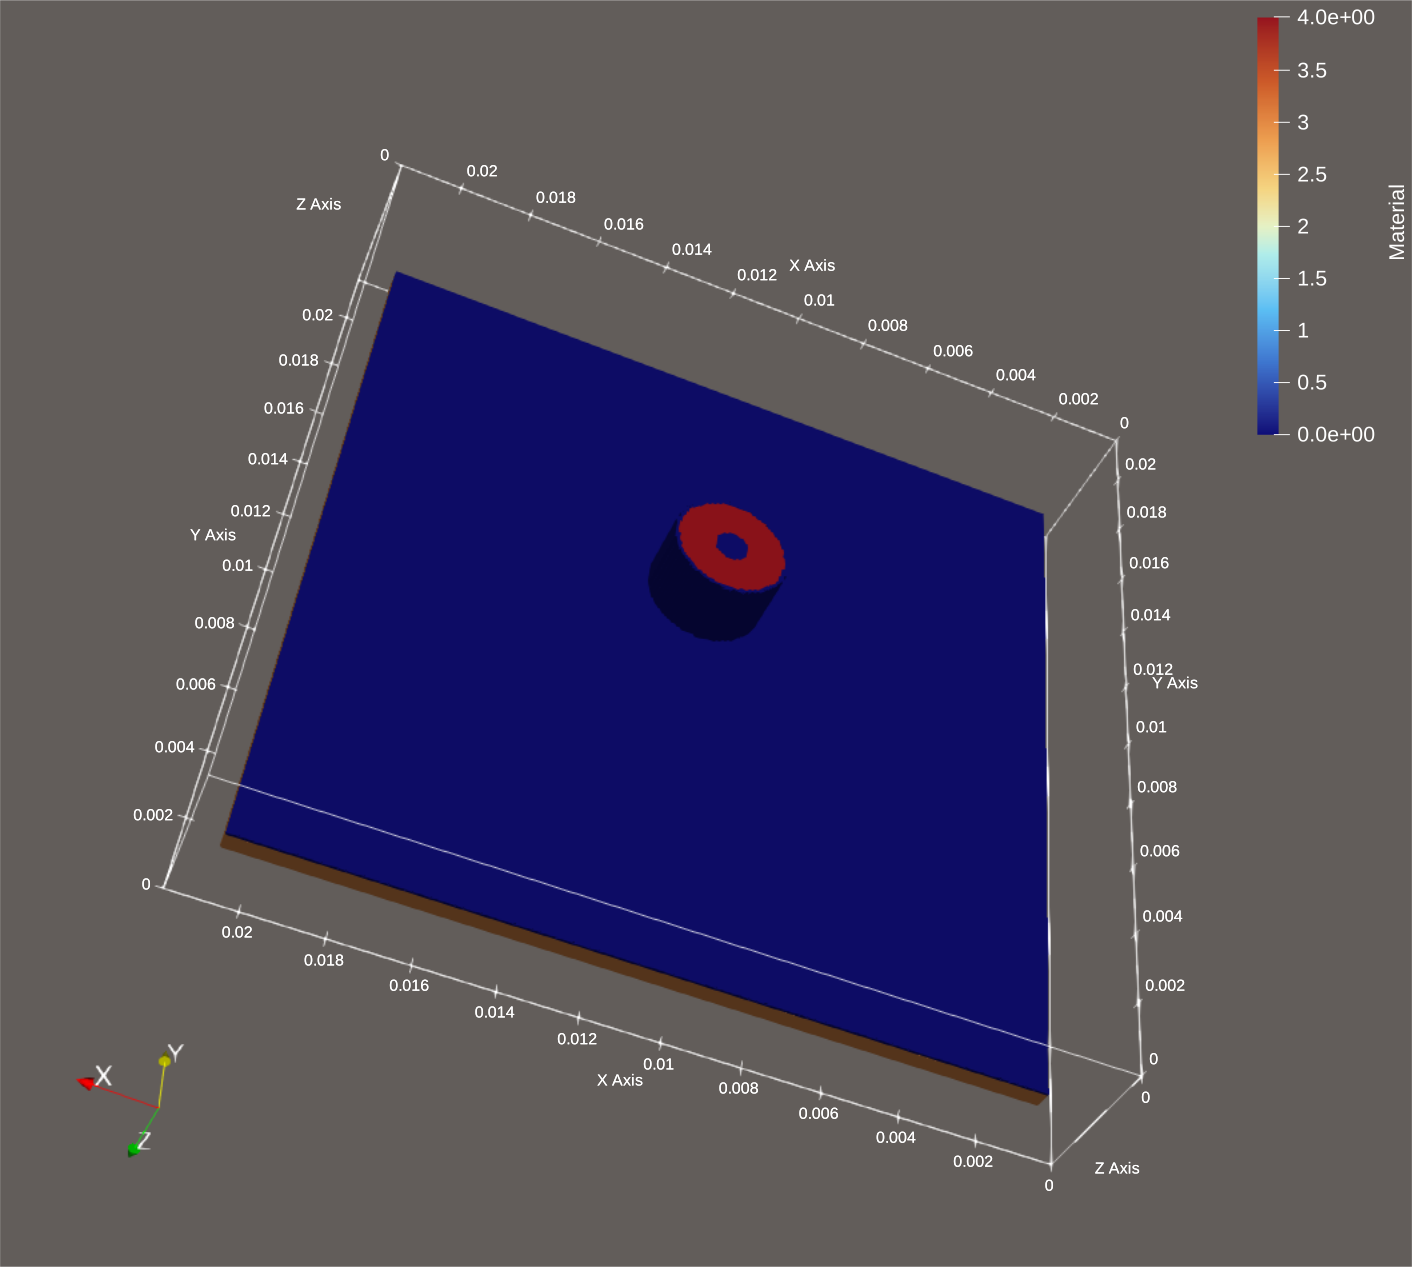
Fig. 84 Coaxial-feed side of the geometry imported into gprMax.
7. Translate and align the port plane
Load the marker and translate it by the same import_origin used for
GeometryObjectsRead:
from gprMax.toolboxes.STEPtoVoxel import load_markers

port = load_markers("patch_output/markers.json")["port1"]
centre = port.model_position(import_origin)
xmin, ymin, _, xmax, ymax, _ = port.model_bounds(import_origin)

def snap(value):
    return round(value / dl) * dl

zport = snap(centre[2])
port_p1 = (snap(xmin), snap(ymin), zport)
port_p2 = (snap(xmax), snap(ymax), zport)
The CAD plane has a very small export tolerance in its normal direction. The
code above collapses that thickness to the nearest Yee-grid plane. Inspect the
selected slice and, if necessary, move it one cell into a uniform section of
the coaxial guide. The axis supplied by the marker is reliable, but the
normal sign is not a source-polarity convention.
The resulting port_p1 and port_p2 can define an eigenmode port or
another source appropriate to the feed. See Eigenmode ports and S-parameter analysis for modal
port and virtual-waveguide excitation. A CAD marker deliberately does not
choose this physics on behalf of the user.
Limitations
Solid voxelisation cannot reproduce zero-thickness sheets as physical material volumes.
Thin-solid preservation applies when a complete component would otherwise be empty. It cannot recover every thin branch of a larger component or an arbitrarily oriented subcell sheet.
CAD tessellation and voxelisation necessarily staircase curved and oblique surfaces.
Approximate material grouping is a convenience suggestion and does not establish material identity.
Very fine grids are memory intensive because the final material array is dense.
Part names depend on exporter metadata. A fallback recovers flat AP242 shape representation names when OpenCascade exposes only generated label paths.
Material overlap priorities must be checked for nested or intersecting assembly components.